Astribot papers on robot self-improvement, world models and always-on agents accepted at CoRL 2026
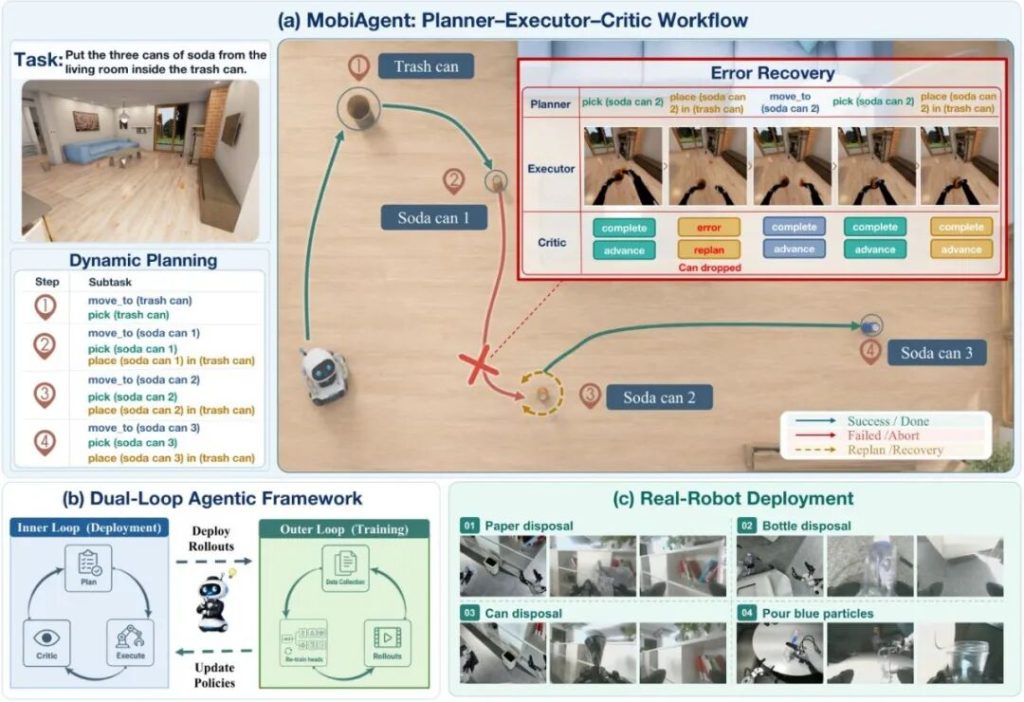
Astribot, an embodied AI company, said three papers co-authored with universities including the University of Hong Kong and the University of Tokyo have been accepted at the 10th Conference on Robot Learning (CoRL 2026), being held in Austin, Texas, from Nov. 9 to 12. The papers address autonomous improvement during real-world deployment, predictive action generation based on latent world models, and perception, memory and dual-arm coordination in long-running online operation — three capabilities the company says general-purpose robots need to work reliably over time. In MobiAgent: Dual-Loop Recursive Policy Self-Improvement for Long-Horizon Mobile Manipulation, Astribot proposes a dual-loop agent framework for long-horizon mobile manipulation. During deployment, a vision-language model handles rolling task planning, skill-specific action experts execute operations, and a...
 AGIBOT
 Figure AI
 UBTECH