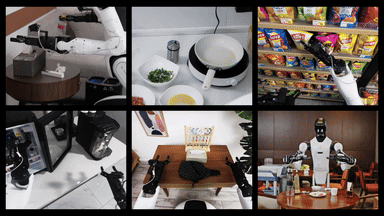
AGIBOT open-sourced the fourth installment of its AGIBOT WORLD 2026 dataset series, “Physical Reasoning,” describing it as the first real-world Physical Agent dataset designed to train robots not only to execute actions but also to decide what to do under changing conditions. The company said the dataset marks a shift in task design from manipulation difficulty to decision difficulty, linking goal understanding, process memory and action execution in real-world tasks. It covers nine categories of logical reasoning scenarios and, for the same task, deliberately captures multiple real-world states and execution branches. It provides both high-level question-answer annotations and low-level action trajectories, supporting coordinated training from task decision-making to real-machine execution. The release is the first installment of AGIBOT’s AI WAVE...
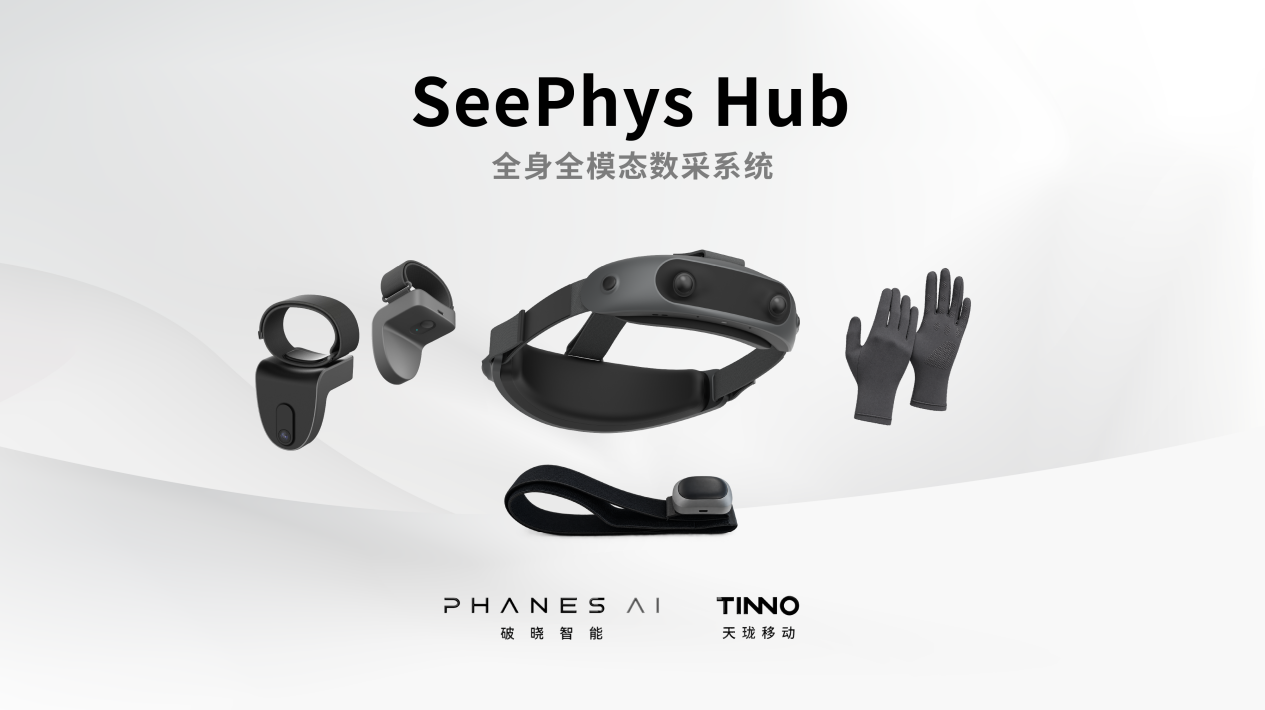
Chinese embodied AI startup PHANES AI, in partnership with Tinno Mobile, launched SeePhys Hub, a wearable full-body multimodal data collection system for robot training. The system comprises a four-camera headband, two wrist bands, three waist-and-leg motion trackers and a tactile glove. PHANES said it can simultaneously collect first-person 360-degree visual data, full hand data including hand pose tracking and high-density touch, and full-body motion data including pose and force. The launch comes as robot data collection has moved from teleoperation to UMI and Ego, with devices becoming lighter and collection simpler. But PHANES said that simplification has come at a cost: Ego can record what the hands are doing, but it struggles to fully capture whole-body movement and cannot sense...
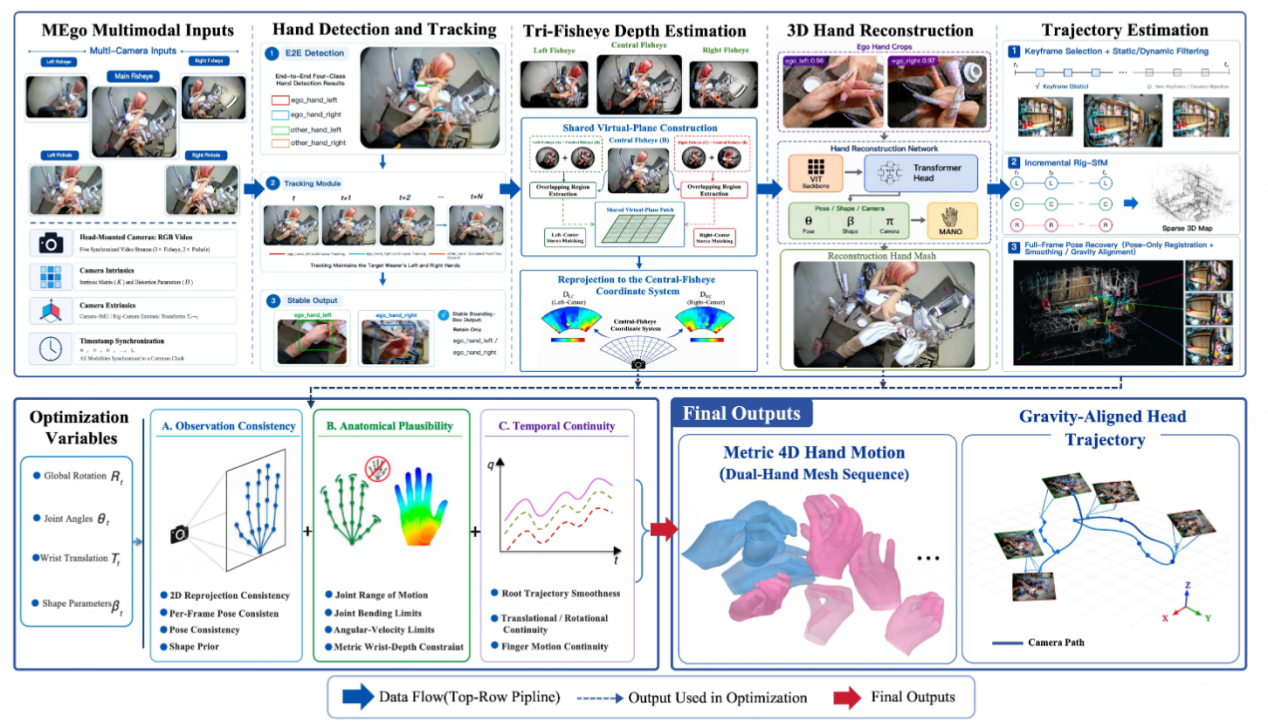
Chinese researchers said they have developed MEgoVista, a framework that converts first-person, or ego, video into 4D motion data for training embodied AI models, addressing a gap between the growing supply of ego video and the precise motion data robots need. The paper was produced by Maniformer Technology, Northwestern Polytechnical University and Xi’an Jiaotong University. Ego video has become an important source of pretraining data because it can be captured in homes, workplaces and other real environments rather than specialized laboratories. But recording an action does not automatically produce usable 4D data, meaning three-dimensional motion over time. Systems must identify the wearer’s hands, reconstruct finger poses and measure how far the hands move in space. MEgoVista is designed as an...
Briefs
Boston Dynamics shows Atlas humanoid robot fitted with wheels
Boston Dynamics has released a video showing its Atlas humanoid robot equipped with wheels. Engineers used custom adapters to mount standard electric scooter wheels onto Atlas's ankle actuators. The modification required no major hardware changes and no rebuild of the robot's software models; engineers simply replaced the feet with wheels in simulation. The wheeled Atlas can jump and spin and perform lateral sprints, the video shows.
D-Robotics, Infinigence AI partner on open-source embodied AI infrastructure
D-Robotics and Infinigence AI announced a strategic partnership to integrate the open-source embodied AI infrastructure matrix RLark, RLinf, RPent and APXInf with D-Robotics' Sunrise chip family and RoboGo software platform. The collaboration will support model training, device management, agent operation and edge deployment.
Ant Lingbo to hold first developer conference on Nov. 16
Ant Lingbo will hold the closing ceremony of its first Embodied Large Model Challenge and its first Developer Conference on the afternoon of Nov. 16. The challenge attracted 1,855 teams and 3,252 participants, with 15 teams comprising 59 contestants advancing to a 48-hour real-robot hackathon final in Shanghai based on the open-source LingBot-VLA 2.0 model.
Amazon forms home robot team to develop "unprecedented" product, report says
Amazon is assembling a home robotics team to develop an "unprecedented robot product" expected to navigate changing home environments and operate autonomously around family members, according to a report. The disclosure is a development plan, not a product launch or listing announcement, the report said.
J.P. Morgan sees U.S. humanoid robot output reaching 300,000-400,000 units by 2030
J.P. Morgan expects U.S. humanoid robot production to reach 300,000 to 400,000 units by 2030 and about 1.5 million units by 2035 as the industry shifts from demonstrations to commercial deployment. Labor shortages, improving economics and rising production capacity are driving adoption in manufacturing, logistics and warehousing, where companies are seeking to automate repetitive tasks, the bank said.
GenRobot AI raises $100 mln in new funding round
Chinese robot startup GenRobot AI said it has completed a new $100 million funding round, with participation from both industrial and financial investors. Industrial investors include SAIC Motor, Malaysia's Eastworlds, Baidu Group, Shoucheng Holdings and GALBOT, while financial investors include Guanghe Venture Capital, SUNHELM, CITIC Jinshi Investment, Zhongzheng Investment, CCB International and Huatai Zijin. Founded in May 2025, Jianzhi Robotics focuses on multimodal data collection and governance technologies and has completed multiple previous funding rounds, according to the company.
LiberAI launches Liber-0 world action model
Physical-world-model startup LiberAI has released Liber-0, a world action model pretrained on more than 2.2 million hours of human experience data. In 600 real-robot tests across 60 tasks randomly generated by GPT-6, the model achieved a 36% overall success rate without collecting robot demonstration data specifically for the test tasks. When combined with human manipulation data collected via data gloves, the model outperformed one trained only on full real-robot data even with 75% less real-robot data, LiberAI said.
Honor sets up robot subsidiary with 100 mln yuan capital
Honor Device Co., Ltd. has wholly owned a newly registered robot subsidiary, Shenzhen Honor Singularity Intelligent Technology Co., Ltd., with registered capital of 100 million yuan, according to corporate registration information. The subsidiary's business scope covers the manufacture and sale of service and consumer robots, research and development of intelligent robots, sales of AI hardware and development of AI application software, among other areas.
Separately, Honor's Lightning D1 robot won the robot category at the Beijing Yizhuang humanoid robot half-marathon on April 19, 2026, in 50 minutes 26 seconds, with Honor's participating robots sweeping the top three places.
RobotHOT brings China & Global Robotics Insights. Explore robotics, embodied‑intelligence updates, startup news and industry analysis for professionals worldwide.
 AGIBOT
 Figure AI
 UBTECH