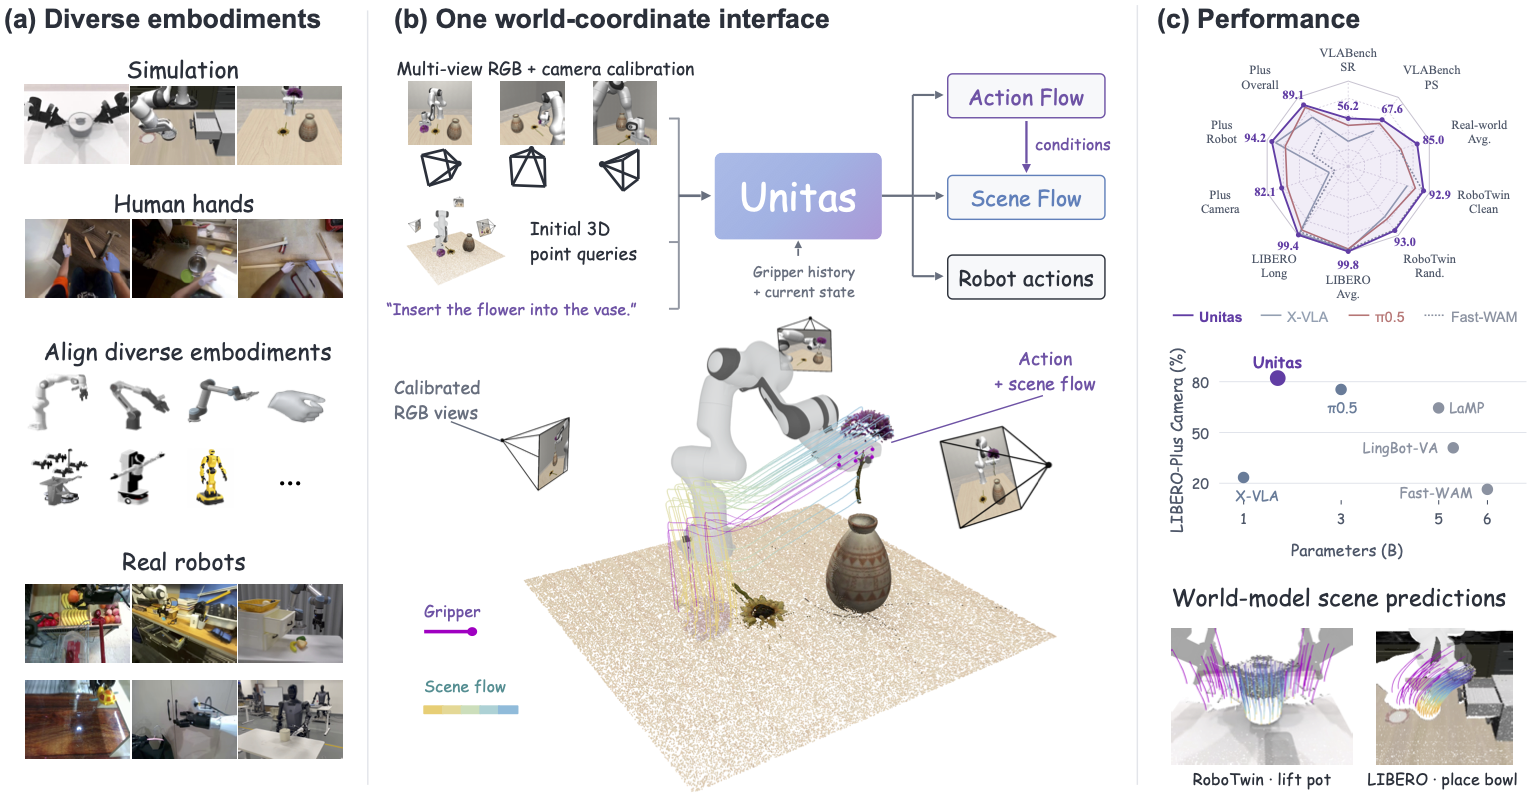
DexForce launches 3D-native robot world model UNITAS, reports benchmark gains
DexForce, an Chinese embodied-AI developer, has unveiled UNITAS, a 3D-native world action model for robot manipulation, saying it is designed to give robots a unified representation of the physical world. The company described UNITAS as the first robot-task-native 3D world model. UNITAS is built on a central premise: just as large language models unify diverse knowledge through text, embodied AI needs a native space for physical experience. DexForce argues that space should be the 3D physical world itself, rather than 2D images or latent features from which 3D relationships must be inferred. The model jointly represents observation, action and scene change in a single 3D coordinate system. Observation corresponds to the 3D positions of objects; action flow corresponds to the...
 the 2026 Bund Summit