2 Articles
Tags :LingBot-Touch
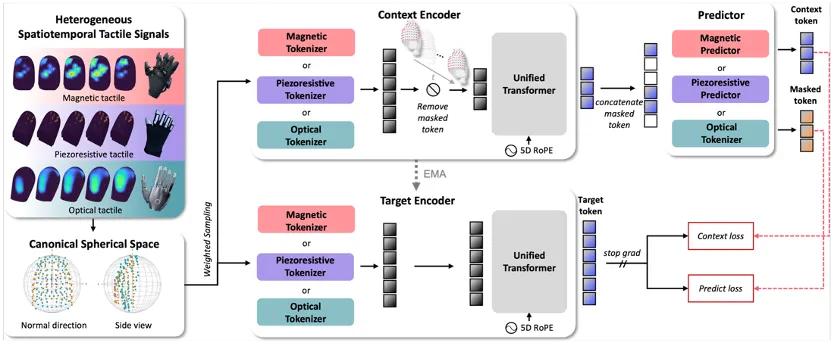
Ant Lingbo Technology released LingBot-Touch, a tactile foundation model pretrained on nearly 5,000 hours of real tactile data. It converts magnetic, vision-based and piezoresistive signals into a unified representation for dexterous hands and action models, adding touch sensing for fine manipulation. The model and code are open-sourced on Hugging Face, GitHub and ModelScope.
Ant Lingbo Technology said it has open-sourced LingBot-Touch, a tactile foundation model designed to give robot “brains” the contact sensing needed for fine manipulation, based on nearly 5,000 hours of real tactile data. The model covers three mainstream sensing principles — magnetic, vision-based and piezoresistive tactile sensing — and converts their different raw signals into a common tactile representation for use across dexterous hands and action models, the company said. The release extends Ant Lingbo’s embodied AI stack from visual perception and task reasoning to fingertip sensing. LingBot-Touch has been integrated with LingBot-VLA, the company’s vision-language-action model, according to Ant Lingbo. Tactile sensing is increasingly seen as a complement to vision in robotic manipulation. In tasks such as unscrewing a...
 AGIBOT
 Figure AI
 UBTECH