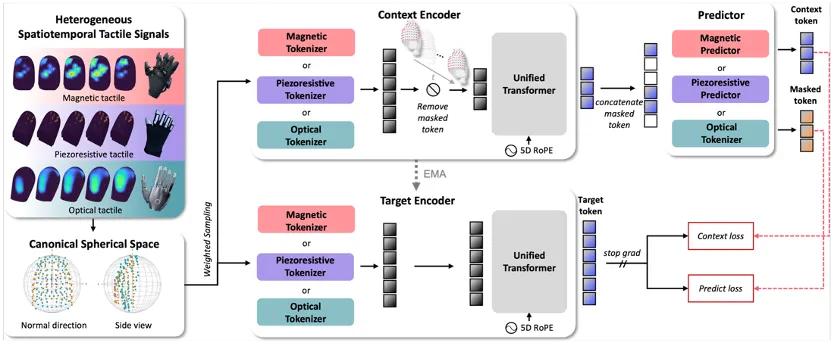
Ant Lingbo Technology released LingBot-Touch, a tactile foundation model pretrained on nearly 5,000 hours of real tactile data. It converts magnetic, vision-based and piezoresistive signals into a unified representation for dexterous hands and action models, adding touch sensing for fine manipulation. The model and code are open-sourced on Hugging Face, GitHub and ModelScope.
Ant Lingbo releases tactile foundation model LingBot-Touch
Related Articles
 Ant Lingbo unveils LingBot-Touch, a pretrained tactile foundation model for dexterous manipulation
- Ant Lingbo’s embodied AI brain powers real-world robotics deployments at 2026 Inclusion · Conference on the Bund
- UBTech wins 88.9 mln yuan Shaoxing robot education project
- Anthropic withdraws pricing details from IPO filing sent to bankers
- ACE ROBOTICS deploys dual-brain architecture in hotel laundry
- Musk says Tesla Optimus deliveries to start around end-2027, possibly via rental
- Swancor warns shares overheated after 100% rally; robot business still small
- Swancor’s Primebot rolls out 10,000th personal robot
 AGIBOT
 Figure AI
 UBTECH