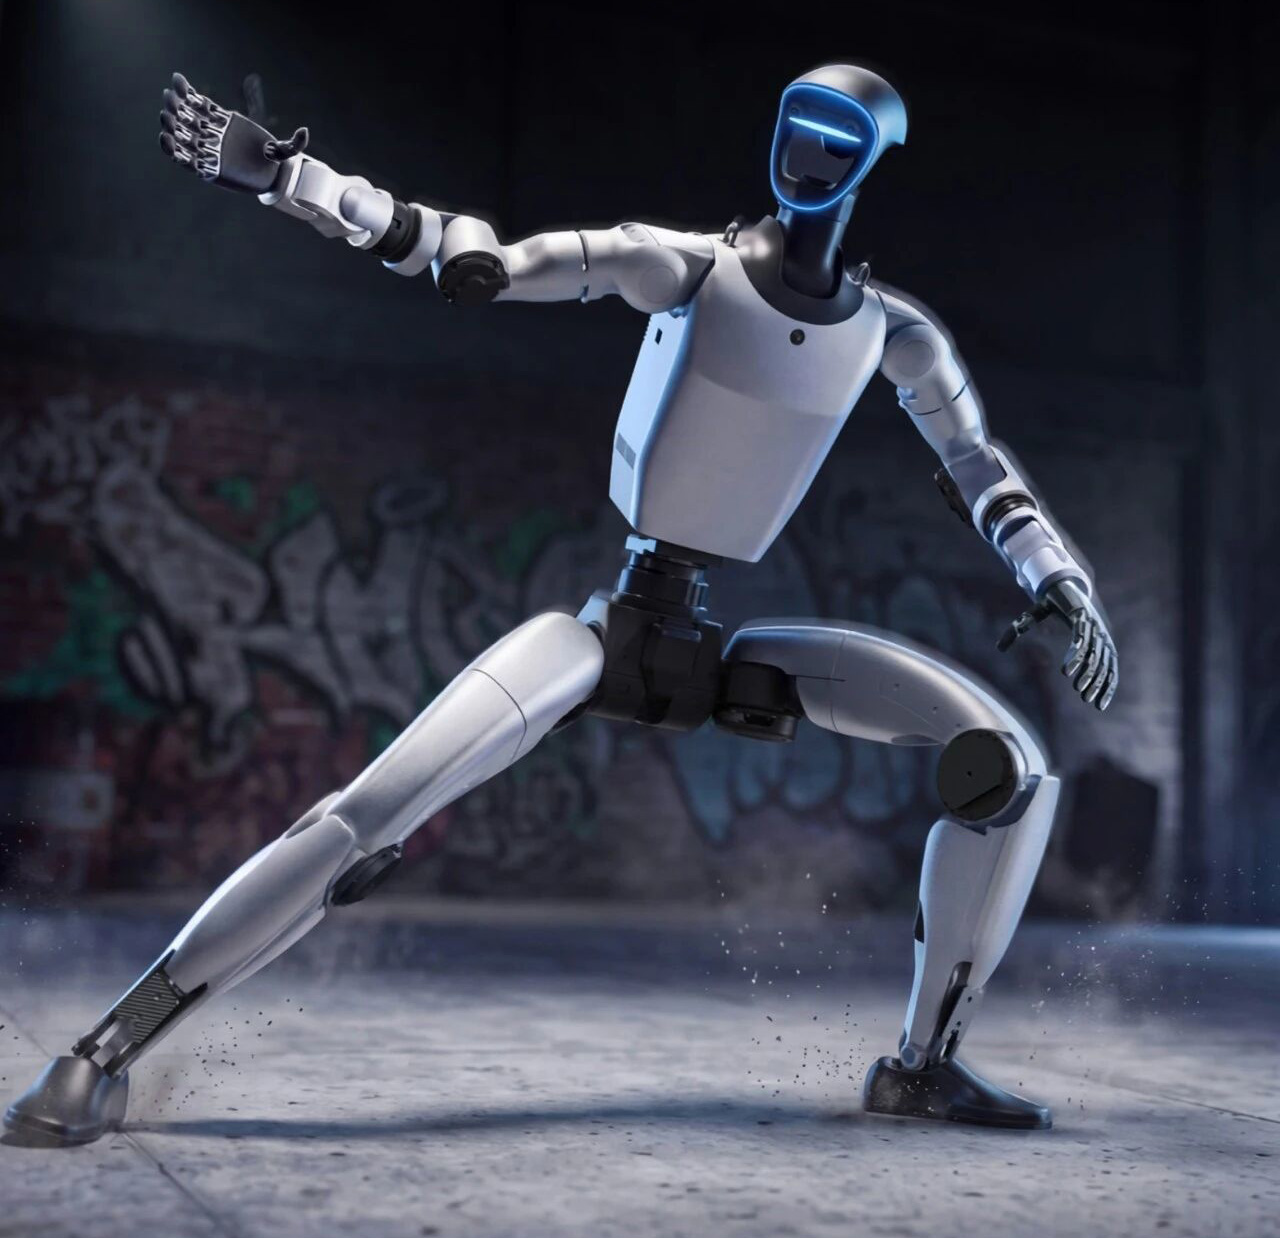
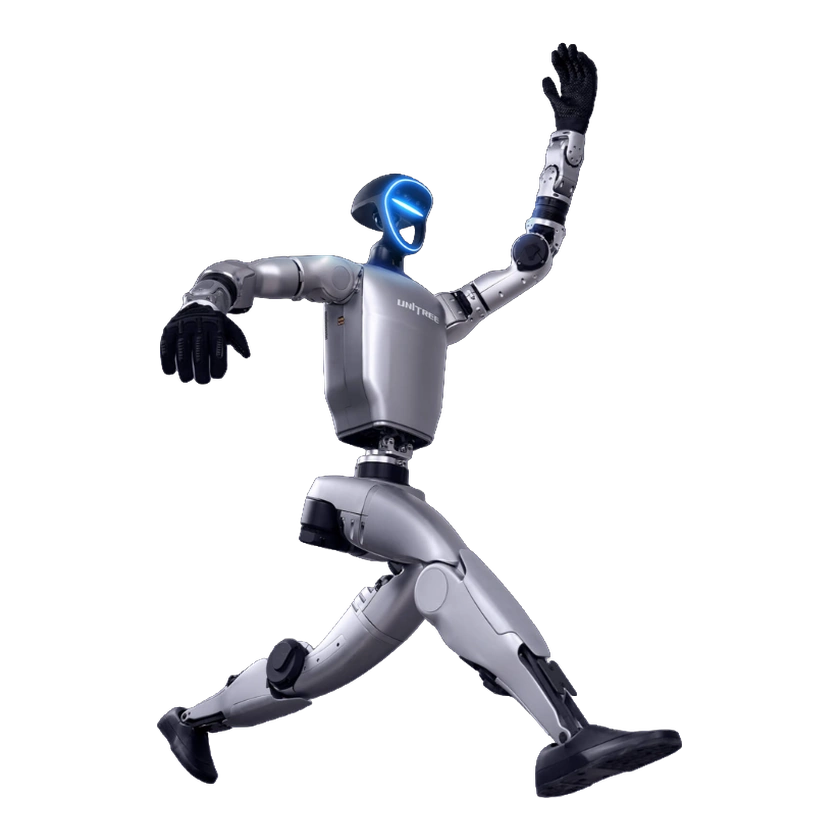
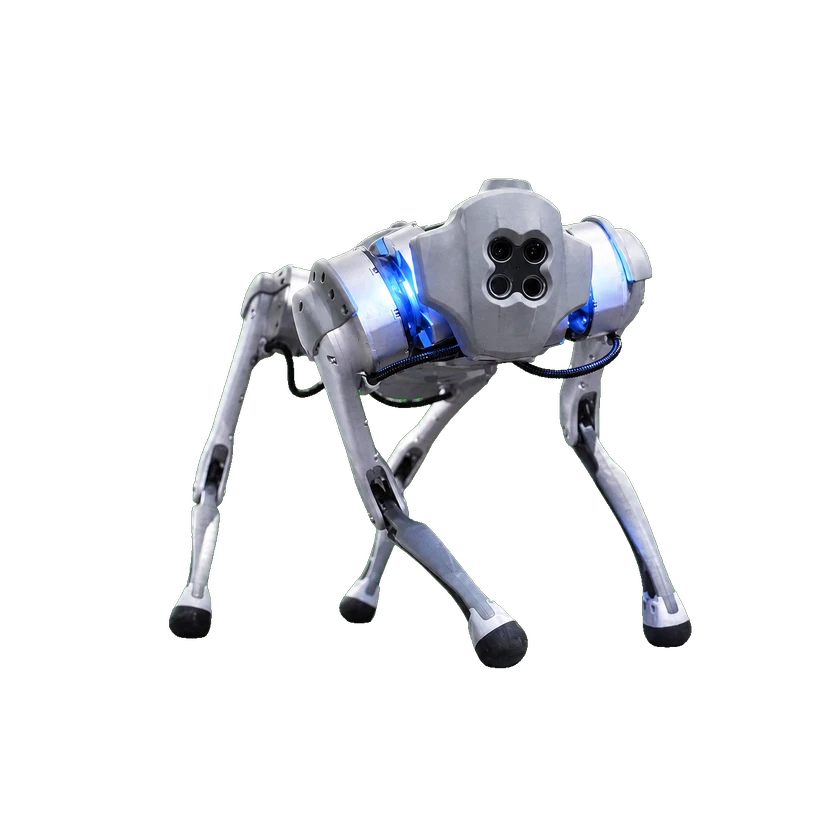
Unitree Robotics said it has fully open-sourced UnifoLM-WLA-1.0, an embodied foundation model that uses a single model to coordinate desktop and whole-body mobile manipulation, supporting cross-task and cross-end-effector generalization.
Unitree open-sources UnifoLM-WLA-1.0 embodied foundation model
Related Articles
 Unitree Robotics updates business status, lifts registered capital by 11% >
- Unitree unveils upgraded G1+ humanoid robot at 95,000 yuan
- Unitree G1
- Unitree Go1 Pro
- Unitree H2
- Unitree open-sources upgraded UnifoLM-WLA-1.0 humanoid foundation model
- Unitree claims world first with world-model-driven autonomous humanoid combat
- Unitree Robotics surges 629% on STAR Market debut, valued at CNY444.91 bln

 the 2026 Bund Summit