3
Astribot
a Leading AI robotics company, empower billions of people with AI robotic partners
Chinese embodied AI startup Astribot has raised 1 billion yuan in a new funding round, valuing the rope-driven robot maker at 15 billion yuan. Toposcend Capital, a unit of Shenzhen Investment Holdings, led the round. Hongtai Fund, Ninghai Xingtaihe Fund managed by Guanghua Sunshine, Soliton Capital and existing shareholder Xianmu followed on. It was Astribot’s fourth round in six months. Its valuation rose from 10 billion yuan to 15 billion yuan in three months, a rare pace even in China’s hot humanoid robot sector. Astribot said proceeds will fund model upgrades, hiring, commercial deployment, capacity and its three-in-one full-stack architecture spanning an AI model, embodied operating system and rope-driven body. Founder and CEO Lai Jie said investors were important “fellow...
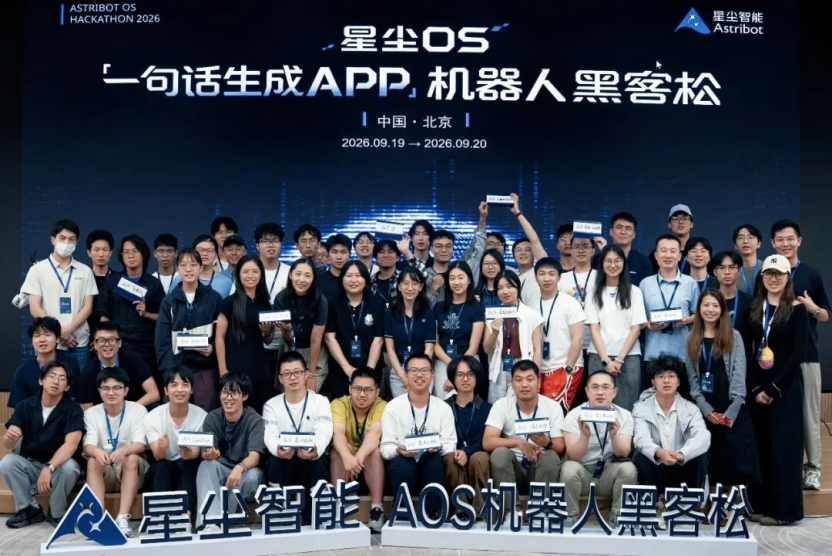
BEIJING, Sept 28 – Chinese embodied AI company Astribot announced the winning apps from the second stop of its Astribot OS hackathon, where 15 teams produced runnable robot applications in 36 hours under a format that generates robot apps from a single sentence. The apps covered elderly care, entertainment and scientific research. Astribot said all were deployed on real robots without teams writing low-level control systems from scratch, marking a step from embodied AI research toward scenario-based applications. Organizers and mentors said the event showed a shift from expert customization to platform assembly. Developers built on Astribot OS’s packaged Meta/Skill modules, SDK, motion control and safety capabilities, rather than handling motion control, communications and hardware drivers themselves. “This is not...
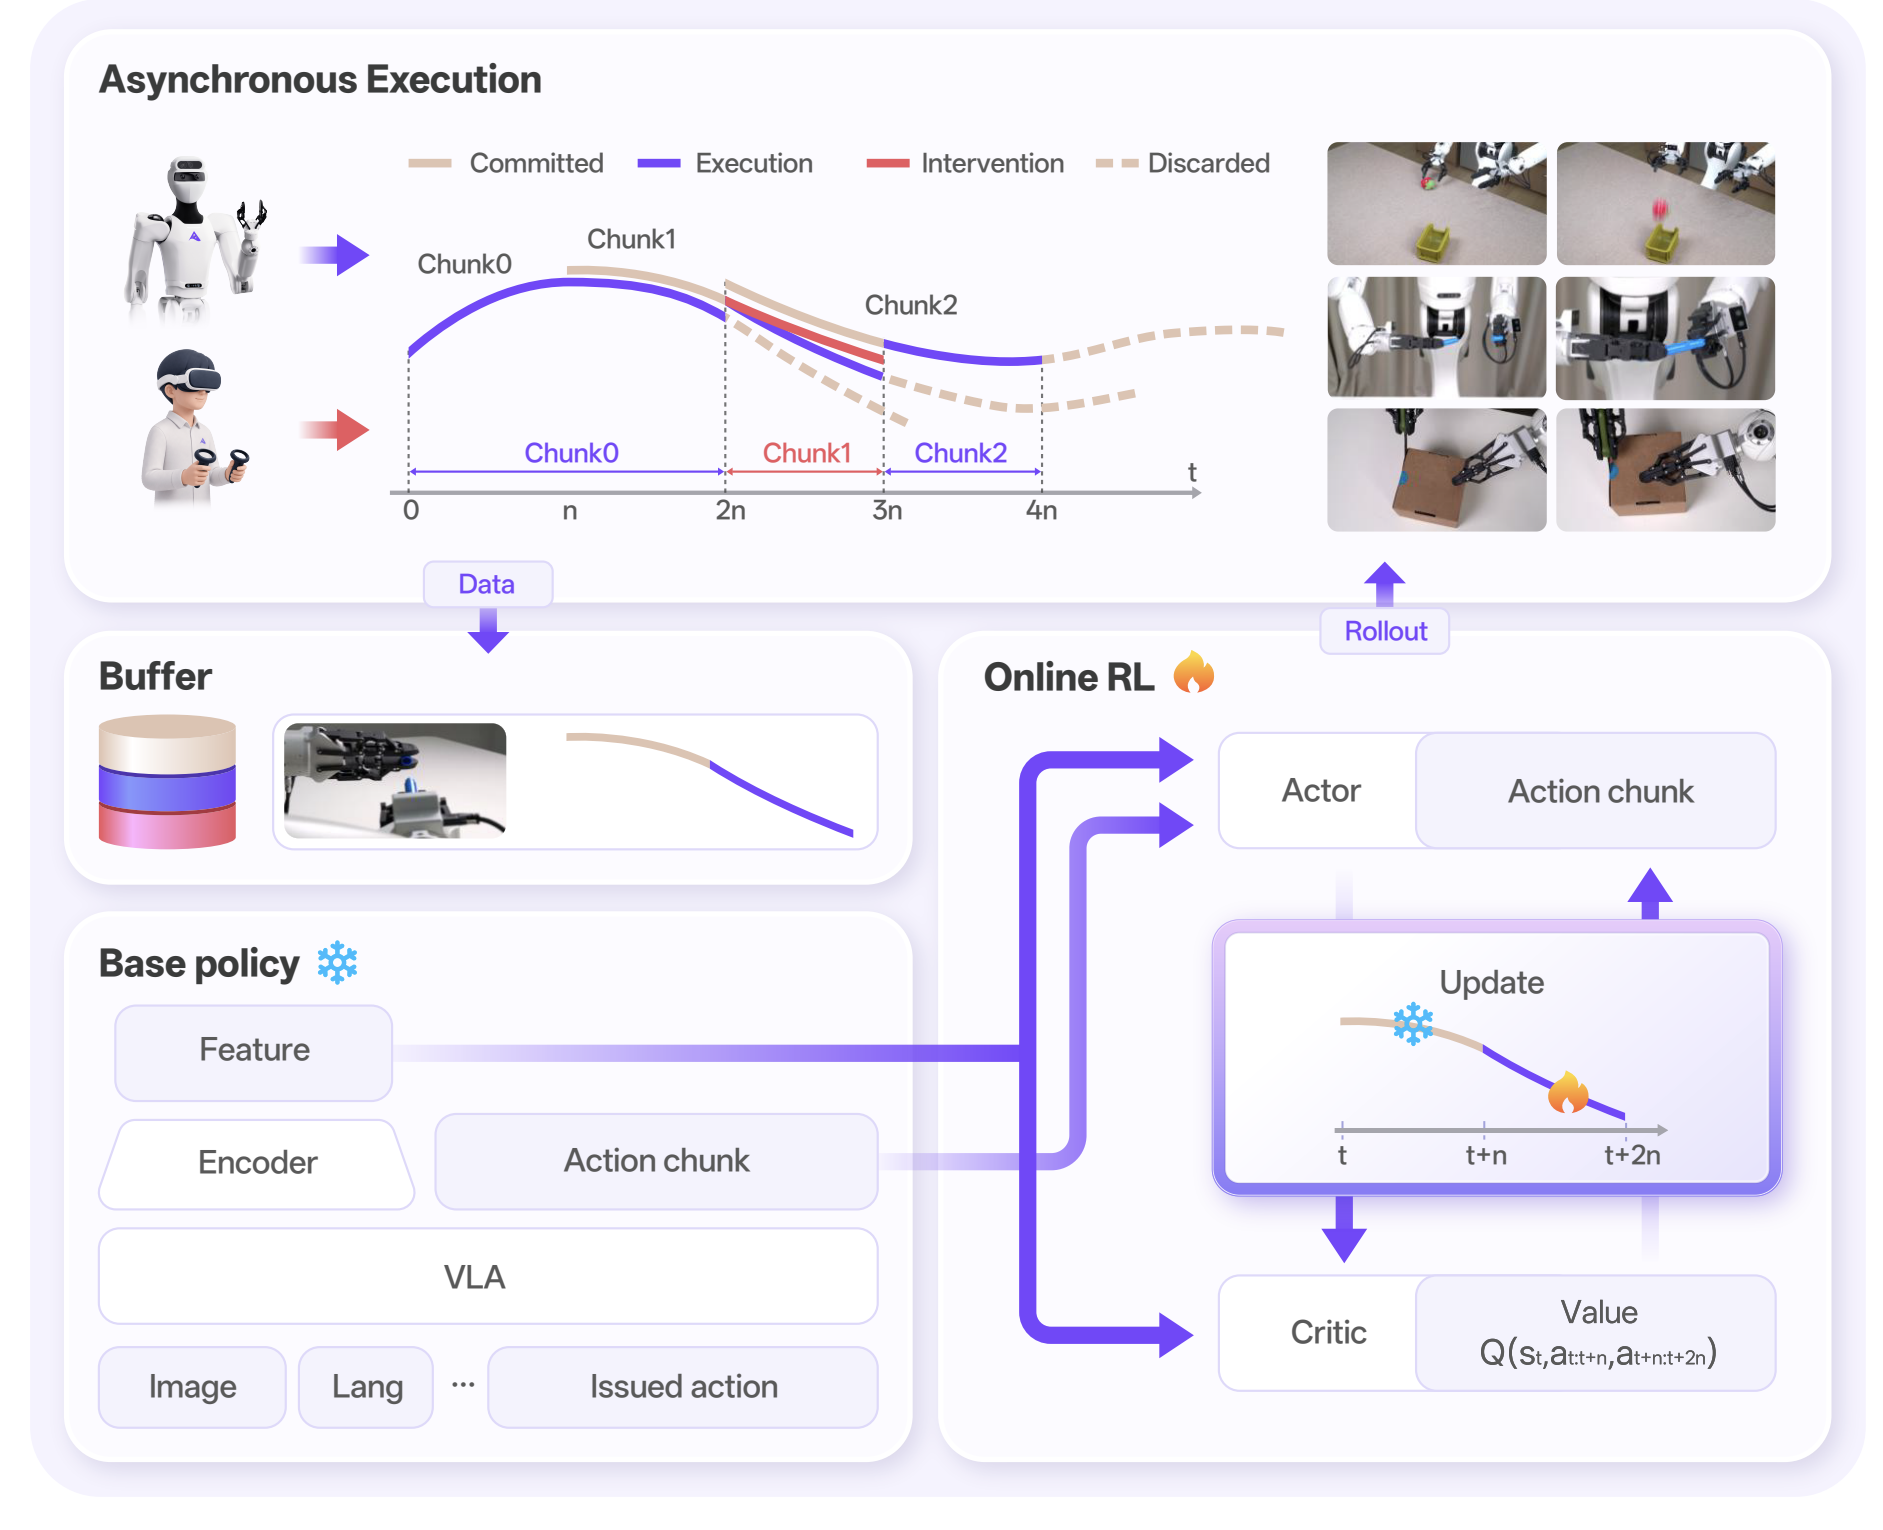
Astribot, a Chinese robotics startup, has unveiled SmoothRL, an online reinforcement learning framework designed to train policies during asynchronous execution – a growing reality for embodied AI deployments where inference and action run at different frequencies. The work, led by the company’s foundation model team, addresses a fundamental mismatch: when a robot receives new action chunks before previous ones finish, conventional RL that updates on entire chunks ends up crediting or blaming actions that were never actually executed. The framework partitions each action chunk into three regions – committed (already fixed), execution (actually performed), and discarded (overwritten by later inference) – and backpropagates gradients only through the execution region. This ensures that optimisation mirrors the robot’s real experience. SmoothRL also...

 AGIBOT