Runway AI has released Praxis-1, a general-purpose robot action model, with open weights available to developers under the Apache 2.0 license. The model is a 27-billion-parameter mixture-of-experts diffusion transformer that predicts video and actions jointly.
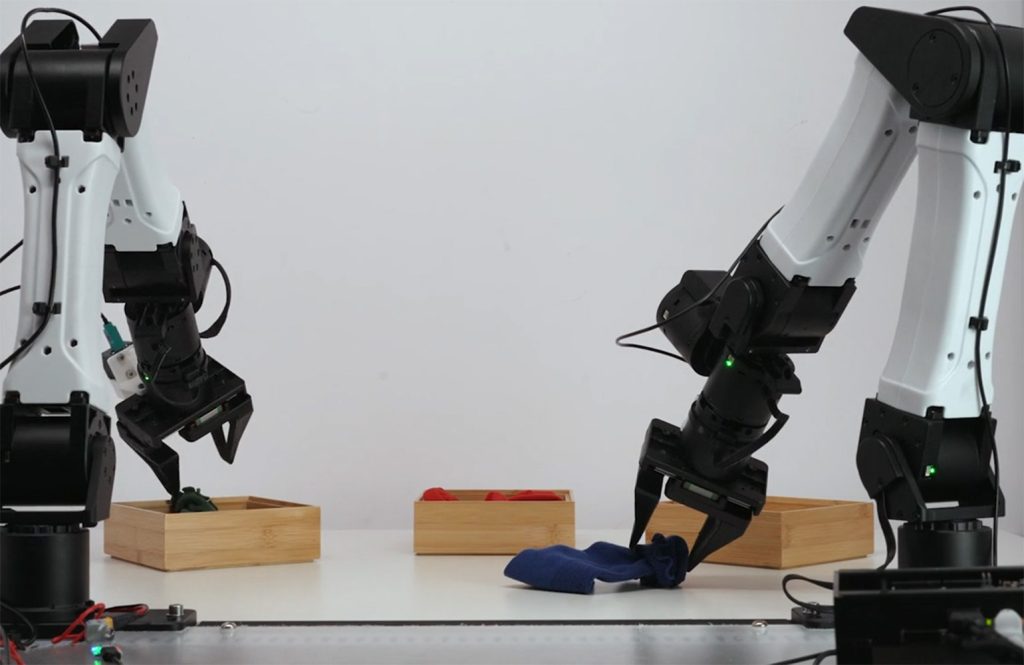
Praxis-1 is available on GitHub, Hugging Face with native LeRobot support and vLLM-Omni, with inference hosted on Reactor. Runway released weights, inference and fine-tuning code for commercial use, supporting full fine-tuning and LoRA. The model runs out of the box on NVIDIA hardware, from data-center H100 and B200 GPUs to RTX 5090, RTX PRO 6000 and Jetson Thor on robots.
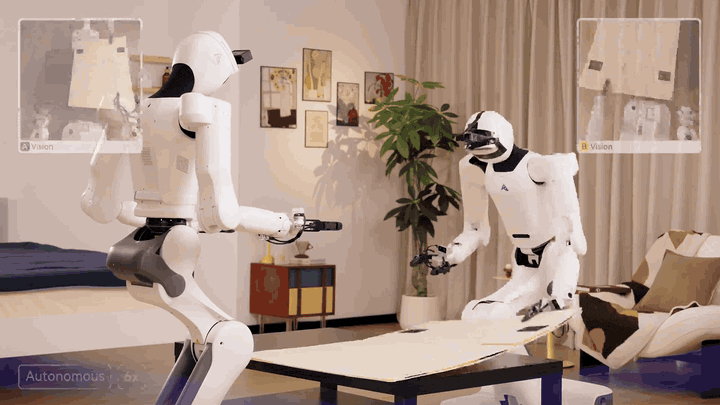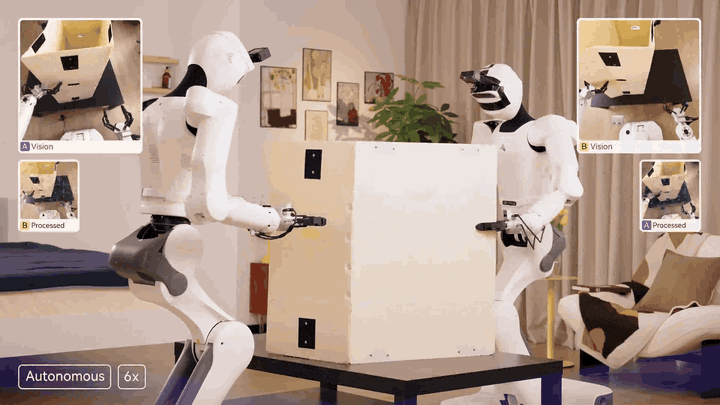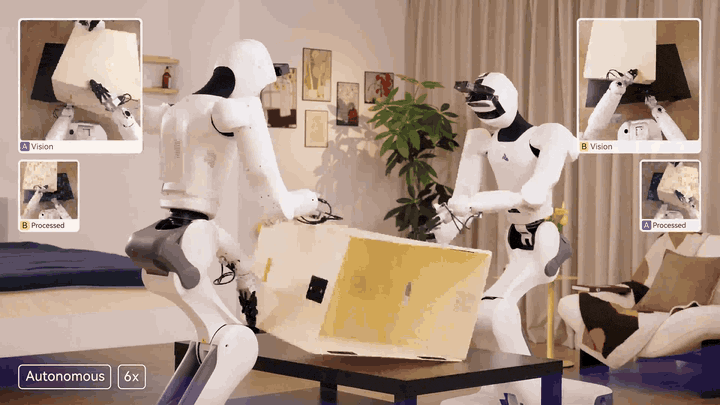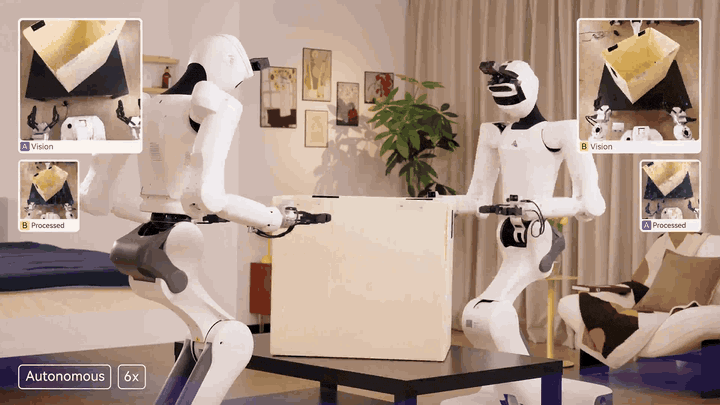
Partners Noble Machines, Standard Bots and Ultra have tested the model on a legged humanoid, a six-axis industrial arm and a dual-arm warehouse robot. Runway said a single Praxis-1 checkpoint adapted to multiple body types with light fine-tuning, while LoRA can adapt it to a user’s own body, cameras and tasks without retraining the full model.
On the RoboLab-120 benchmark, Praxis-1 achieved a 46.2% success rate across 1,200 episodes, compared with 42.9% for FLUX 3 Action, 36.8% for Cosmos3 Nano and 28.0% for π0.5, ranking fifth. After fine-tuning on Google’s RT-1 robot, which was not in its training data, Praxis-1 reached 80.0% on SimplerEnv, versus 52.4% for the original RT-1 policy.
Runway said Praxis-1 is built on its video foundation models, learning how the world works before learning to act. Video prediction remains part of the training objective, with the model predicting the next scene and generating motion to reach it.
 AGIBOT
 Figure AI
 UBTECH